JoltGym
A high-performance, MuJoCo-compatible physics simulation engine for reinforcement learning, built on Jolt Physics with Vulkan rendering and Python (Gymnasium) bindings.
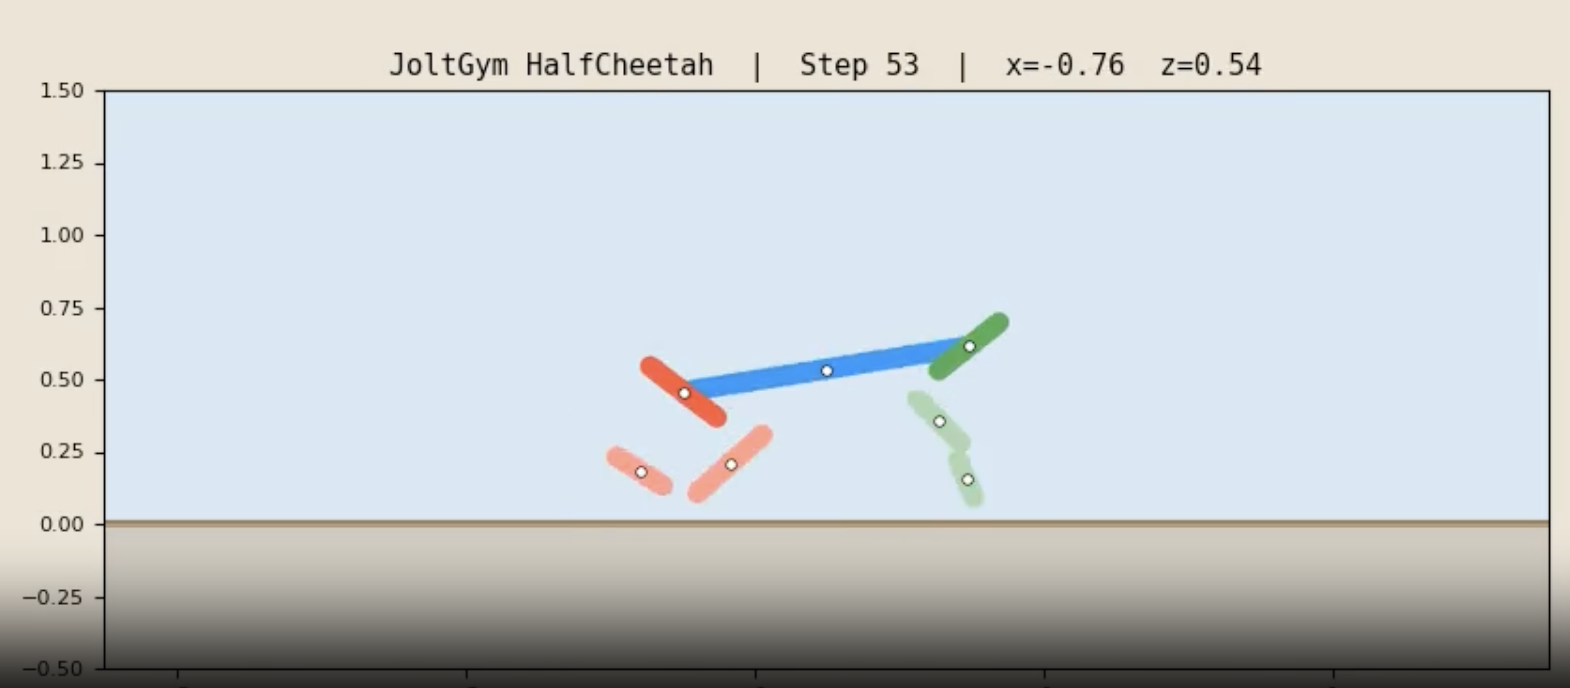
Key Features
- Jolt Physics backend -- C++17, deterministic, excellent multicore scaling
- MJCF compatibility -- loads MuJoCo XML models (HalfCheetah, Humanoid)
- Gymnasium API -- drop-in
env.reset()/env.step()/env.render()interface - Vulkan renderer -- SDL2 window + Dear ImGui debug overlay (macOS via MoltenVK, Linux, Windows)
- Offscreen rendering -- headless
rgb_arraymode for training servers - WorldPool -- N parallel
PhysicsSysteminstances stepped from C++, ~73K env-steps/sec - Multi-agent -- multiple robots in a single shared world with collision
- Zero-copy Python -- pybind11 + NumPy, hot path entirely in C++
Architecture Overview
Python (Gymnasium API)
  +-- pybind11 bindings (zero-copy NumPy)
       +-- C++ Core
            |-- MJCF Parser (tinyxml2)
            |-- Physics (Jolt Physics)
            |-- Renderer (Vulkan + SDL2 + ImGui)
            +-- WorldPool (N parallel PhysicsSystem instances)
Environments
| Environment | Description | Obs Dim | Act Dim |
|---|---|---|---|
JoltGym/HalfCheetah-v0 |
2D planar cheetah locomotion | 17 | 6 |
JoltGym/Humanoid-v0 |
3D bipedal humanoid locomotion | 45 | 17 |
JoltGym/CheetahRace-v0 |
N multi-agent cheetahs racing | N*17 | N*6 |
Quick Example
import joltgym

env = joltgym.make("JoltGym/HalfCheetah-v0")
obs, info = env.reset(seed=42)

for _ in range(1000):
    action = env.action_space.sample()
    obs, reward, terminated, truncated, info = env.step(action)
    if terminated or truncated:
        obs, info = env.reset()

env.close()
Performance
JoltGym scales to 3.8x faster than MuJoCo at 64+ parallel environments via C++ parallel stepping, eliminating Python subprocess overhead entirely.
| Environments | JoltGym (C++ WorldPool) | MuJoCo (AsyncVectorEnv) |
|---|---|---|
| 1 | 11,935 sps | 17,477 sps |
| 8 | 33,292 sps | 11,024 sps |
| 64 | 64,503 sps | 18,608 sps |
| 256 | 73,606 sps | 18,287 sps |
See Performance for full benchmarks and analysis.
License
MIT